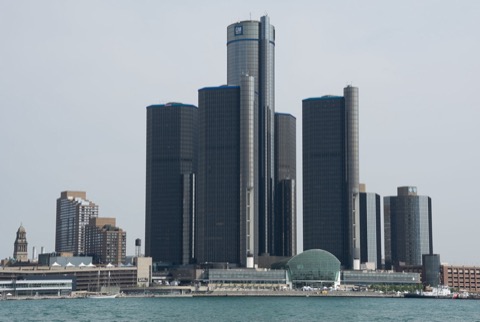
通用汽车公司(General Motors Company,GM)成立于1908年9月16日,自从威廉·杜兰特创建了美国通用汽车公司以来,通用汽车在全球生产和销售包括别克、雪佛兰、凯迪拉克、GMC、五菱、宝骏以及霍顿等一系列品牌车型并提供服务。2014年,通用汽车旗下多个品牌全系列车型畅销于全球120多个国家和地区,包括电动车、微车、重型全尺寸卡车、紧凑型车及敞篷车。 2018年11月,将在北美地区大幅裁员约14700人,预计有可能一举关闭在美国本土及加拿大的5家工厂。 2019年9月16日,近5万通用汽车工人零点起开始罢工。这是他们12年来首次全国范围大罢工。双方达成新的4年协议后,工人们将会复工。
Externally solidified crystals (ESCs) can easily form during high pressure die casting (HPDC) of aluminum alloys if the process is not properly controlled, leading to significant reduction of casting quality and performance. This study explores seven machine learning (ML) models, including decision tree, random forest, logistic regression, neural network, K-nearest neighbors (KNN), support vector machine (SVM), and naïve Bayes classifier. The random forest and classification tree models showed the highest accuracy of 95
Active fault management of the integration of Cyber-Physical Systems (CPSs), Digital Twins (DTs), and AI-driven sensors needs a secure and uniform framework. In relevance, the paper presents a hybrid Variational Autoencoder-Generative Adversarial Network (VAE-GAN)-based model with a redesigned Generative AI-Driven Sensor Fusion (GAI-SF) architecture. The proposed architecture combines the streams of multivariate sensor data and preempts anomalies before performance levels may be detected as degraded. Experimental validation based on Tennessee Eastman Process (TEP) and NASA turbofan engine data shows that it is up to 80 times better than classic fusion techniques in F1-score, and lowers the detection latency by some 40%. In addition to predictive performance, GAI-SF is fully compatible with ISO/IEC JTC 1/ SC 42, 3GPP SA6, and ETSI MEC standards, meaning it can be used in secure, interoperable, and AI-controlled deployment in next-generation 5G/6G CPS ecosystems.
Learning data-efficient object dynamics models for robotic manipulation remains challenging, especially for deformable objects. A popular approach is to model objects as sets of 3D particles and learn their motion using graph neural networks. In practice, this is not enough to maintain physical feasibility over long horizons and may require large amounts of interaction data to learn. We introduce PIEGraph, a novel approach to combining analytical physics and data-driven models to capture object dynamics for both rigid and deformable bodies using limited real-world interaction data. PIEGraph consists of two components: (1) a Physically Informed particle-based analytical model (implemented as a spring–mass system) to enforce physically feasible motion, and (2) an Equivariant Graph Neural Network with a novel action representation that exploits symmetries in particle interactions to guide the analytical model. We evaluate PIEGraph in simulation and on robot hardware for reorientation and repositioning tasks with ropes, cloth, stuffed animals and rigid objects. We show that our method enables accurate dynamics prediction and reliable downstream robotic manipulation planning, which outperforms state of the art baselines.
This paper addresses the challenge of developing a realistic urban-driving simulator to accurately model agent behaviors, a crucial component for self-driving car development. Most previous simulators focus on the plausibility of sensor data synthesis, whereas the plausibility of driving behaviors is poorly explored. To tackle this problem, we propose a hierarchical architecture, which comprises (i) a high-level intention simulation summarizing driving scenarios and (ii) a low-level policy trained by reinforcement algorithms to refine plans. Unlike existing simulators, our approach captures diverse behaviors, even sub-optimal ones, vital for robust policy training and evaluation. We also highlight the importance of interactive simulations over static scenarios for realistic policy development. Extensive experiments demonstrate that our approach significantly improves long-term behavior prediction and closed-loop simulation, enhancing the realism and diversity of urban-driving simulations. The videos of this work are available in our project page: href{https://sites.google.com/ucsd.edu/h-sim/home}{https:/ /sites.google.com/ucsd.edu/h-sim/home}.
A track fitting pipeline is presented that converts a measured racetrack point cloud into a closed, C^4 differentiable, three-dimensional surface model suitable for high-fidelity Modelica race-car optimization. The surface is a Monge patch, parametrised by a curvilinear arc-length coordinate measured along the minimum-curvature line (MCL) and a signed lateral offset, with a height polynomial of user-selectable degree capturing the cross-sectional elevation profile. The choice of MCL as the reference line is deliberate since anchoring the same surface on the geometric centre-line can cause adjacent normals to cross inside the drivable region on tight corners. The resulting non-injective parametrisation assigns multiple curvilinear addresses to the same three-dimensional point and returns invalid road geometry. The MCL is obtained from a quadratic program that minimises integrated curvature subject to track-boundary, periodicity, and jerk-regularisation constraints. By reducing total curvature while remaining within the track bounds, the MCL moves the region of parametrisation breakdown outside the drivable strip on all circuits studied, keeps the normal map injective across the full track width, and yields a more linear time-to-arc-length transformation for minimum lap-time problems. The fitted surface and the associated track widths are exported as periodic piecewise-quintic C^4 B-splines, solved as a nonlinear program.




